
Computer Graphics- Cheatsheet

Homogeneous coordinates
Adding a fourth term: (w) makes it easier to work in 3D euclidian space.
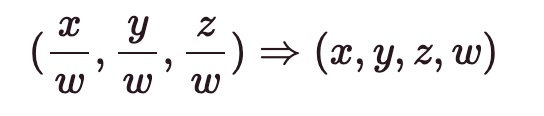
Why? Here's a long list of reasons, but a couple key points:
- 3D scaling, rotation, and translation operations can be represented as a single linear transform (4x4 matrix)
- A direction (Infinity) can be represented in 3D space: (x,y,z,0)
Transformations
Translation
for a point (p):
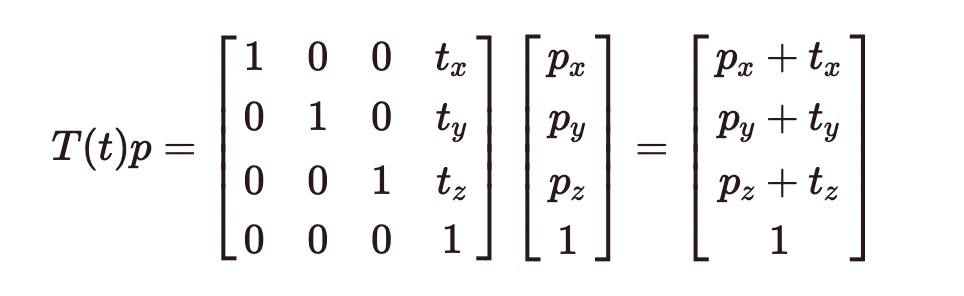
for a vector (v):
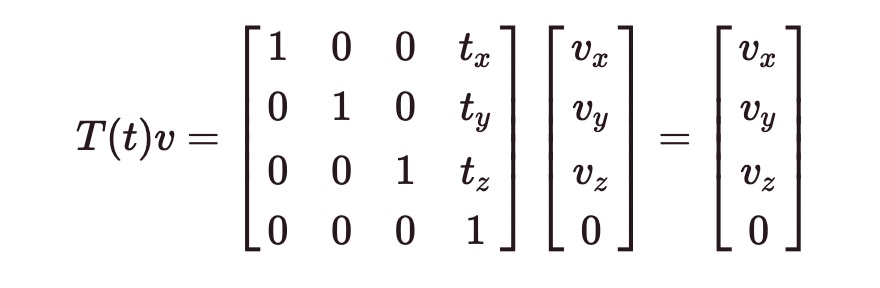
inverse transform: (T^{-1}(t) = T(-t))
Scaling
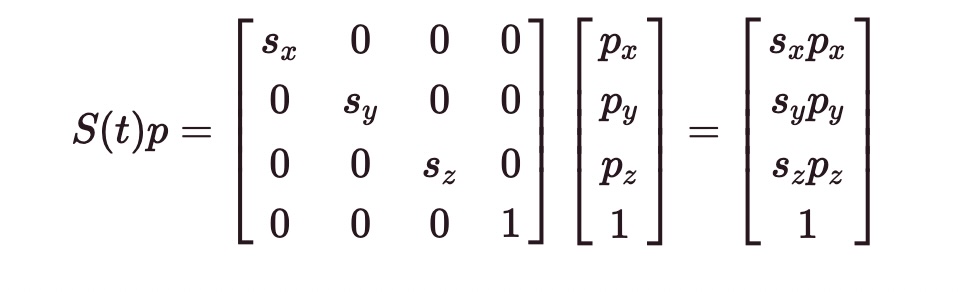
Rotation
When applying individual rotations (yaw, pitch, roll), the order of rotation operations is important. To get around this problem use axis-angle representation.
If you only need to rotate around a single axis, then applying the rotation transform can be straightforward.
Rotation matrices for each axis:
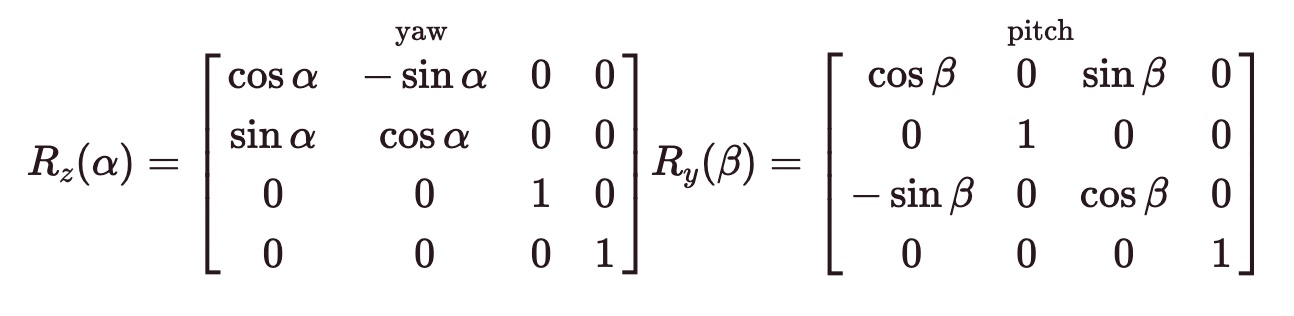
The inverse of a rotation matrix corresponds to its transpose.
Coordinate Systems
Local space, World space, View space, Clip space, Screen space
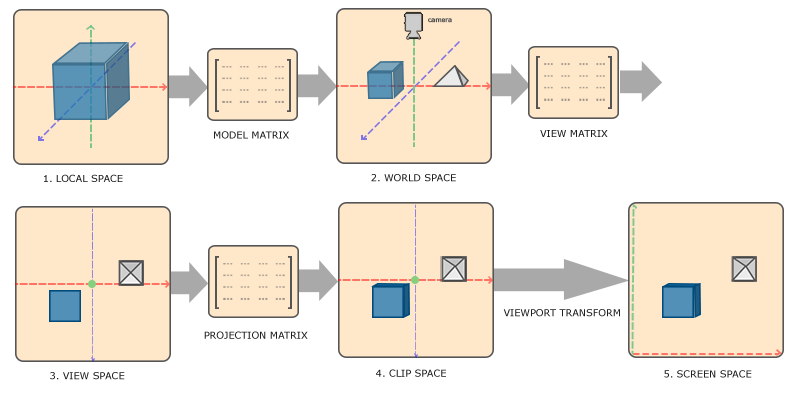
The relationships between the various spaces - Source: LearnOpenGL.com
More on Coordinate Systems
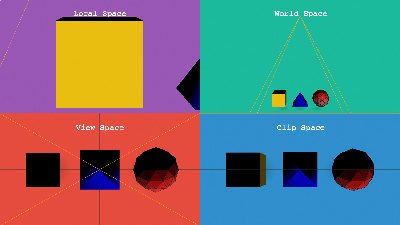
The same scene as viewed in the different coordinate systems
Perspective vs Orthographic Projection
perspective / orthographic projection. near plane / far plane. clipping.
Screen Space
You can use the Viewport Transform to get to Screen Space (actual pixels)
Combining Transformations
To transform a vertex coordinate to clip coordinates:
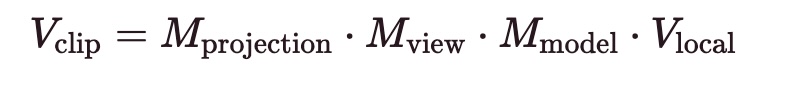
Other Useful References
Coordinate systems we commonly reference for development.
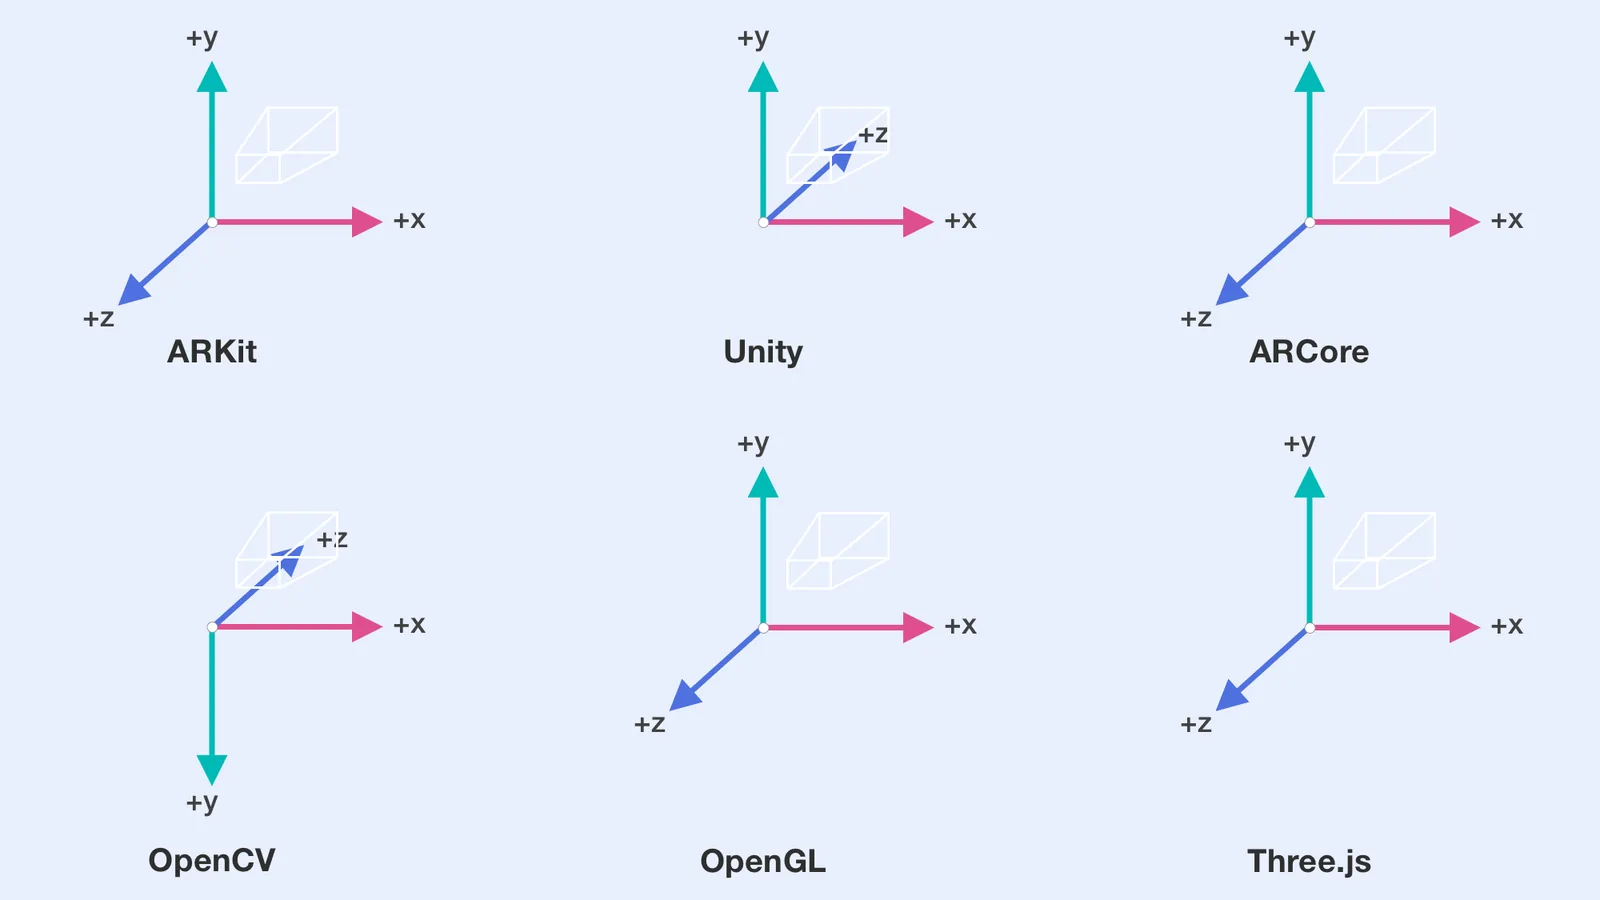
Coordinate Systems for various frameworks
Pinhole camera model
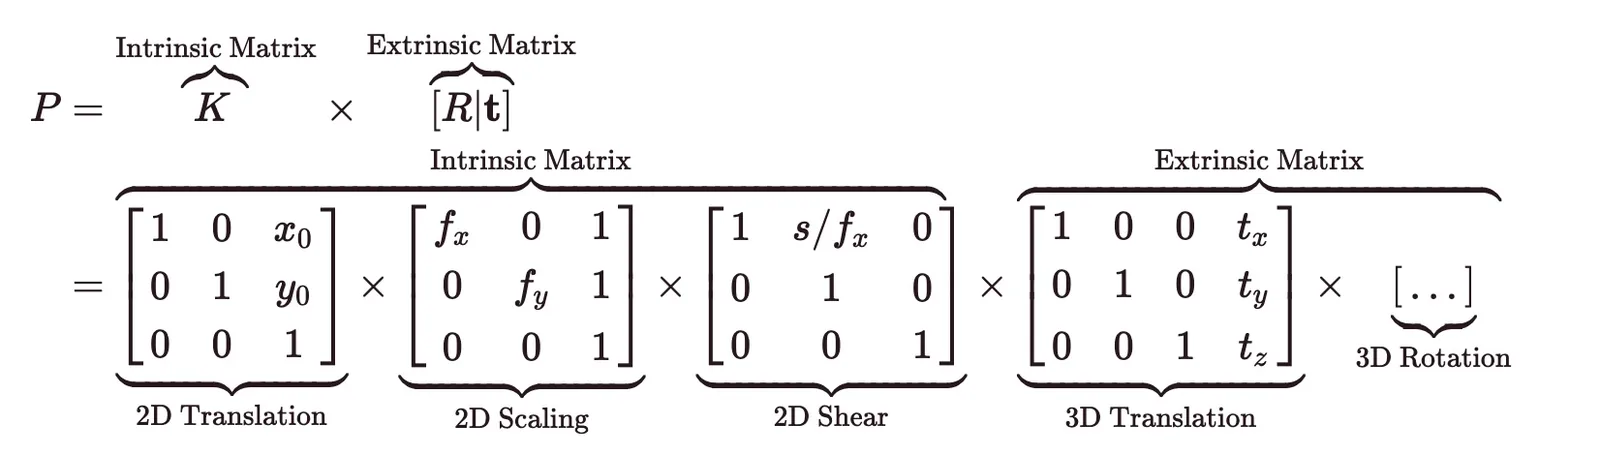
Source: Kyle Simek's excellent computer vision blog
FAQs
How do I get the camera direction from a given view matrix?
Column 2 of the view matrix is the camera's -Z direction.
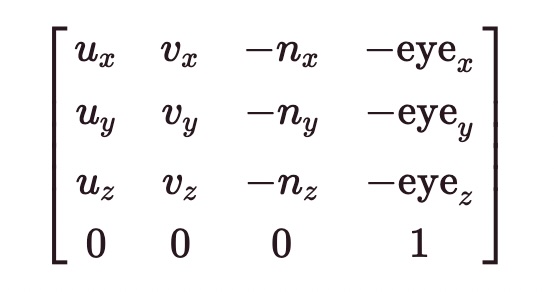
Where (u), (v), and (n) are the normalized vectors for the camera referential. (u) is the up vector, (n) is the direction the camera is looking at, and (v) is perpendicular to both (n) and (u).
Download this article
Get the markdown source for offline reading